Hauptseite | Klassenhierarchie | Auflistung der Klassen | Auflistung der Dateien | Klassen-Elemente | Datei-Elemente | Zusätzliche Informationen

M_LAYER.CPP Dateireferenz

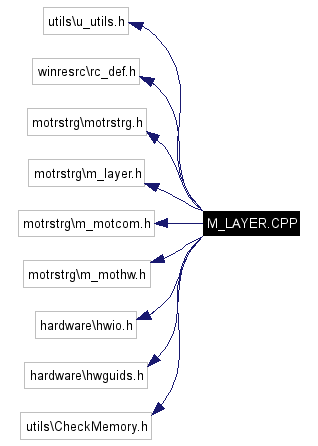
#include "utils\u_utils.h"
#include "winresrc\rc_def.h"
#include "motrstrg\motrstrg.h"
#include "motrstrg\m_layer.h"
#include "motrstrg\m_motcom.h"
#include "motrstrg\m_mothw.h"
#include "hardware\hwio.h"
#include "hardware\hwguids.h"
#include "utils\CheckMemory.h"

Include-Abhängigkeitsdiagramm für M_LAYER.CPP:

Include dependency graph

Funktionen

LPCSTR _MOTORCLASS WINAPI mlGetVersion (void)
HINSTANCE _MOTORCLASS WINAPI mlGetInstance (void)
void _MOTORCLASS CALLBACK mSavePosition (UINT, UINT, DWORD, DWORD, DWORD)
int _MOTORCLASS WINAPI mGetScanSize (void)
void _MOTORCLASS WINAPI mStartMoveScan (int tic, int)
LPLONG _MOTORCLASS WINAPI mGetMoveScan (void)
int _MOTORCLASS WINAPI mGetMoveFinishIdx (void)
BOOL _MOTORCLASS WINAPI mlInitializeMotorsDLL (void)
BOOL _MOTORCLASS WINAPI mlSetAxis (int axis)
int _MOTORCLASS WINAPI mlGetAxis (void)
int _MOTORCLASS WINAPI mlGetIdByName (EAxisType at)
EAxisType _MOTORCLASS WINAPI mlParsingAxis (LPSTR axisname)
BOOL _MOTORCLASS WINAPI mlIsAxisValid (EAxisType type)
BOOL _MOTORCLASS WINAPI mlIsServerOK (void)
int _MOTORCLASS WINAPI mlGetAxisNumber (void)
double _MOTORCLASS WINAPI mlGetOffset (int mid)
void _MOTORCLASS WINAPI mlSetAngleDefault (void)
void _MOTORCLASS WINAPI mlOptimizingDlg (void)
UINT _MOTORCLASS WINAPI mlGetDigits (int mid)
 neu Kullmann+Reinecker: Ermittelt die Nachkommastellengenauigkeit für Angle- und Speed-Ausgaben (siehe DFmt)

double _MOTORCLASS WINAPI mlGetValue (int mid, EValueType vtype)
double _MOTORCLASS WINAPI mlGetAngleRelativeMin (int mid)
double _MOTORCLASS WINAPI mlGetAngleRelativeMax (int mid)
BOOL _MOTORCLASS WINAPI mlMoveToDistance (int mid, double distance)
BOOL _MOTORCLASS WINAPI mlIsMoveFinish (int mid)
void _MOTORCLASS WINAPI mlSetParametersDlg (void)
void _MOTORCLASS WINAPI mlPositionControlDlg (void)
void _MOTORCLASS WINAPI mlSaveModuleSettings (void)
void _MOTORCLASS WINAPI mlInquireReferencePointDlg (BOOL task)
BOOL _MOTORCLASS WINAPI mSetLine (int number, BOOL state)
void _MOTORCLASS WINAPI mlSetRelativeZero (int axis, BOOL yes, double value)
void _MOTORCLASS WINAPI mSetRelativeZero (BOOL yes, double value)
BOOL _MOTORCLASS WINAPI mlIsDistanceRelative (int axis)
BOOL _MOTORCLASS WINAPI mIsDistanceRelative (void)
BOOL _MOTORCLASS WINAPI mIsRangeHit (void)
BOOL _MOTORCLASS WINAPI mMoveByDistance (double angle)
BOOL _MOTORCLASS WINAPI mMoveToDistance (double angle)
BOOL _MOTORCLASS WINAPI mIsMoveFinish (void)
BOOL _MOTORCLASS WINAPI mlGetDistance (int mid, double &distance)
BOOL _MOTORCLASS WINAPI mGetDistance (double &ang)
double _MOTORCLASS WINAPI mlGetDistanceProcess (int axis)
double _MOTORCLASS WINAPI mGetDistanceProcess (void)
UINT _MOTORCLASS WINAPI mGetDigits (void)
 neu Kullmann+Reinecker: Ermittelt die Nachkommastellengenauigkeit für Angle- und Speed-Ausgaben (siehe DFmt)

void _MOTORCLASS WINAPI mStopDrive (BOOL restart)
double _MOTORCLASS WINAPI mGetValue (EValueType vtype)
double _MOTORCLASS WINAPI mGetAngleRelativeMin (void)
double _MOTORCLASS WINAPI mGetAngleRelativeMax (void)
BOOL _MOTORCLASS WINAPI mlSetValue (int axis, EValueType vtype, double value)
BOOL _MOTORCLASS WINAPI mSetValue (EValueType vtype, double value)
EUnitType _MOTORCLASS WINAPI mGetUnitType (void)
BOOL _MOTORCLASS WINAPI mlIsCalibrated (int axis)
BOOL _MOTORCLASS WINAPI mIsCalibrated (void)
void _MOTORCLASS WINAPI mActivateDrive (void)
void _MOTORCLASS WINAPI mlSetCorrectionState (int axis, BOOL onoff)
void _MOTORCLASS WINAPI mSetCorrectionState (BOOL onoff)
LPCSTR _MOTORCLASS WINAPI mlGetAxisName (int axis)
LPCSTR _MOTORCLASS WINAPI mGetAxisName (void)
LPCSTR _MOTORCLASS WINAPI mlGetAxisUnit (int mid)
LPCSTR _MOTORCLASS WINAPI mGetAxisUnit (void)
LPCSTR _MOTORCLASS WINAPI mGetSF (void)
LPCSTR _MOTORCLASS WINAPI mGetDF (void)
int _MOTORCLASS WINAPI mExecuteCmd (LPSTR cmd)
void _MOTORCLASS WINAPI mPushSettings (void)
void _MOTORCLASS WINAPI mPopSettings (EMParameter mp)
BOOL WINAPI DllMain (HINSTANCE hModule, DWORD dwFunction, LPVOID)
Controller * GetController (EDeviceType DeviceID, LPTSTR HardwareID, ControllerList *Controllers, DeviceList *Drivers, DWORD *index)

Variablen

HINSTANCE hModuleInstance
DeviceList MotorDrivers
ControllerList MotorControllers
int nC812
char buf [MaxString]
LPMList _MOTORCLASS lpMList = NULL
TMFunctionTable MFT

Dokumentation der Funktionen

BOOL WINAPI DllMain (  HINSTANCE  hModule,
DWORD  dwFunction,
LPVOID 
) 
 

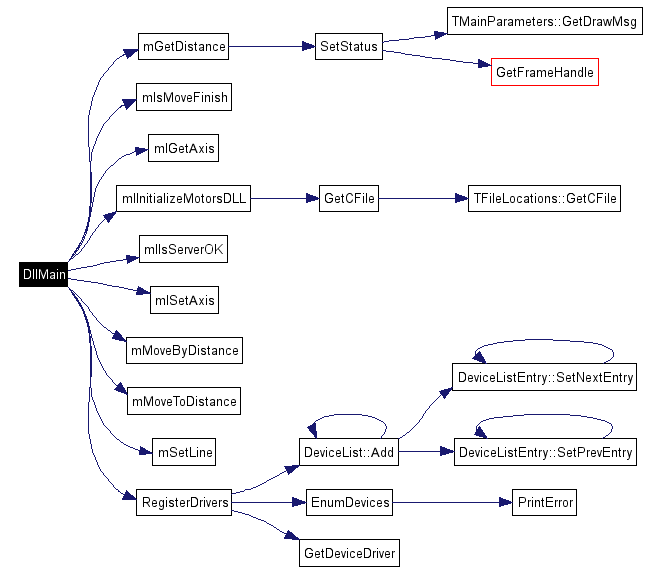
Hier ist der Graph aller Aufrufe für diese Funktion:

Controller* GetController (  EDeviceType  DeviceID,
LPTSTR  HardwareID,
ControllerList *  Controllers,
DeviceList *  Drivers,
DWORD *  index
) 
 

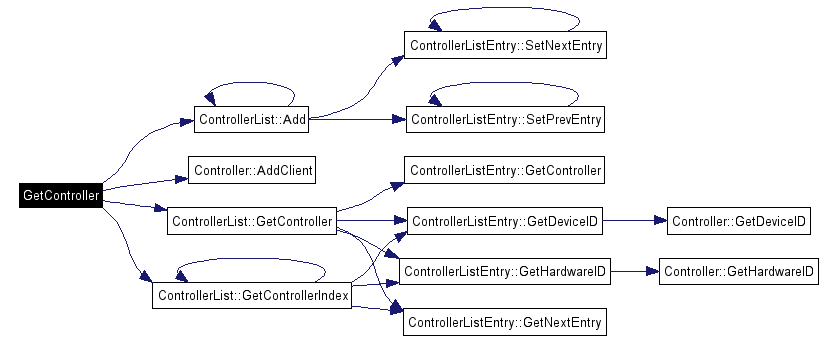
Hier ist der Graph aller Aufrufe für diese Funktion:

void _MOTORCLASS WINAPI mActivateDrive (  void   ) 
 

int _MOTORCLASS WINAPI mExecuteCmd (  LPSTR  cmd  ) 
 

double _MOTORCLASS WINAPI mGetAngleRelativeMax (  void   ) 
 

double _MOTORCLASS WINAPI mGetAngleRelativeMin (  void   ) 
 

LPCSTR _MOTORCLASS WINAPI mGetAxisName (  void   ) 
 

LPCSTR _MOTORCLASS WINAPI mGetAxisUnit (  void   ) 
 

LPCSTR _MOTORCLASS WINAPI mGetDF (  void   ) 
 

UINT _MOTORCLASS WINAPI mGetDigits (  void   ) 
 

neu Kullmann+Reinecker: Ermittelt die Nachkommastellengenauigkeit für Angle- und Speed-Ausgaben (siehe DFmt)

BOOL _MOTORCLASS WINAPI mGetDistance (  double &  ang  ) 
 

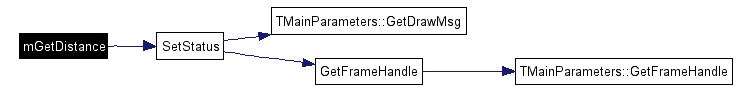
Hier ist der Graph aller Aufrufe für diese Funktion:

double _MOTORCLASS WINAPI mGetDistanceProcess (  void   ) 
 

int _MOTORCLASS WINAPI mGetMoveFinishIdx (  void   ) 
 

LPLONG _MOTORCLASS WINAPI mGetMoveScan (  void   ) 
 

int _MOTORCLASS WINAPI mGetScanSize (  void   ) 
 

LPCSTR _MOTORCLASS WINAPI mGetSF (  void   ) 
 

EUnitType _MOTORCLASS WINAPI mGetUnitType (  void   ) 
 

double _MOTORCLASS WINAPI mGetValue (  EValueType  vtype  ) 
 

BOOL _MOTORCLASS WINAPI mIsCalibrated (  void   ) 
 

BOOL _MOTORCLASS WINAPI mIsDistanceRelative (  void   ) 
 

BOOL _MOTORCLASS WINAPI mIsMoveFinish (  void   ) 
 

BOOL _MOTORCLASS WINAPI mIsRangeHit (  void   ) 
 

double _MOTORCLASS WINAPI mlGetAngleRelativeMax (  int  mid  ) 
 

double _MOTORCLASS WINAPI mlGetAngleRelativeMin (  int  mid  ) 
 

int _MOTORCLASS WINAPI mlGetAxis (  void   ) 
 

LPCSTR _MOTORCLASS WINAPI mlGetAxisName (  int  axis  ) 
 

int _MOTORCLASS WINAPI mlGetAxisNumber (  void   ) 
 

LPCSTR _MOTORCLASS WINAPI mlGetAxisUnit (  int  mid  ) 
 

UINT _MOTORCLASS WINAPI mlGetDigits (  int  mid  ) 
 

neu Kullmann+Reinecker: Ermittelt die Nachkommastellengenauigkeit für Angle- und Speed-Ausgaben (siehe DFmt)

BOOL _MOTORCLASS WINAPI mlGetDistance (  int  mid,
double &  distance
) 
 

double _MOTORCLASS WINAPI mlGetDistanceProcess (  int  axis  ) 
 

int _MOTORCLASS WINAPI mlGetIdByName (  EAxisType  at  ) 
 

HINSTANCE _MOTORCLASS WINAPI mlGetInstance (  void   ) 
 

double _MOTORCLASS WINAPI mlGetOffset (  int  mid  ) 
 

double _MOTORCLASS WINAPI mlGetValue (  int  mid,
EValueType  vtype
) 
 

LPCSTR _MOTORCLASS WINAPI mlGetVersion (  void   ) 
 

BOOL _MOTORCLASS WINAPI mlInitializeMotorsDLL (  void   ) 
 

Hier ist der Graph aller Aufrufe für diese Funktion:

void _MOTORCLASS WINAPI mlInquireReferencePointDlg (  BOOL  task  ) 
 

BOOL _MOTORCLASS WINAPI mlIsAxisValid (  EAxisType  type  ) 
 

BOOL _MOTORCLASS WINAPI mlIsCalibrated (  int  axis  ) 
 

BOOL _MOTORCLASS WINAPI mlIsDistanceRelative (  int  axis  ) 
 

BOOL _MOTORCLASS WINAPI mlIsMoveFinish (  int  mid  ) 
 

BOOL _MOTORCLASS WINAPI mlIsServerOK (  void   ) 
 

BOOL _MOTORCLASS WINAPI mlMoveToDistance (  int  mid,
double  distance
) 
 

void _MOTORCLASS WINAPI mlOptimizingDlg (  void   ) 
 

Hier ist der Graph aller Aufrufe für diese Funktion:

EAxisType _MOTORCLASS WINAPI mlParsingAxis (  LPSTR  axisname  ) 
 

void _MOTORCLASS WINAPI mlPositionControlDlg (  void   ) 
 

void _MOTORCLASS WINAPI mlSaveModuleSettings (  void   ) 
 

void _MOTORCLASS WINAPI mlSetAngleDefault (  void   ) 
 

BOOL _MOTORCLASS WINAPI mlSetAxis (  int  axis  ) 
 

void _MOTORCLASS WINAPI mlSetCorrectionState (  int  axis,
BOOL  onoff
) 
 

void _MOTORCLASS WINAPI mlSetParametersDlg (  void   ) 
 

void _MOTORCLASS WINAPI mlSetRelativeZero (  int  axis,
BOOL  yes,
double  value
) 
 

BOOL _MOTORCLASS WINAPI mlSetValue (  int  axis,
EValueType  vtype,
double  value
) 
 

BOOL _MOTORCLASS WINAPI mMoveByDistance (  double  angle  ) 
 

BOOL _MOTORCLASS WINAPI mMoveToDistance (  double  angle  ) 
 

void _MOTORCLASS WINAPI mPopSettings (  EMParameter  mp  ) 
 

void _MOTORCLASS WINAPI mPushSettings (  void   ) 
 

void _MOTORCLASS CALLBACK mSavePosition (  UINT  ,
UINT  ,
DWORD  ,
DWORD  ,
DWORD 
) 
 

Hier ist der Graph aller Aufrufe für diese Funktion:

void _MOTORCLASS WINAPI mSetCorrectionState (  BOOL  onoff  ) 
 

BOOL _MOTORCLASS WINAPI mSetLine (  int  number,
BOOL  state
) 
 

void _MOTORCLASS WINAPI mSetRelativeZero (  BOOL  yes,
double  value
) 
 

BOOL _MOTORCLASS WINAPI mSetValue (  EValueType  vtype,
double  value
) 
 

void _MOTORCLASS WINAPI mStartMoveScan (  int  tic,
int 
) 
 

void _MOTORCLASS WINAPI mStopDrive (  BOOL  restart  ) 


Variablen-Dokumentation

char buf[MaxString]
 

HINSTANCE hModuleInstance
 

LPMList _MOTORCLASS lpMList = NULL
 

TMFunctionTable MFT
 

ControllerList MotorControllers
 

DeviceList MotorDrivers
 

int nC812


Erzeugt am Sat Nov 13 12:48:27 2004 für XCTL32 von doxygen 1.3.7